6.1. CANopen Overview
CANopen is a real-time, high-speed CAN-based protocol specified by CiA (CAN in Automation) for communicating among multiple nodes. CANopen networks are formed using twisted-pair cabling, where all network nodes can be directly wired together through D-sub connectors.
CANopen EDS (electronic datasheet) files are used to describe the communication parameters and object dictionary of CANopen nodes. Magna-Power Electronics provides this EDS file to customers which contains identifying information, supported communication objects, and parameter settings.
Magna-Power Electronics has implemented basic process data objects (PDOs) for use with our products. Customer PDO remapping is not supported. Layer setting services (LSS) is supported to change the node ID and baud rate of each node.
6.2. Physical Interface
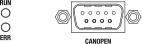
Fig. 6.1 Rear interface
6.2.1. D-sub 9 Port
The DBx Module has a single, male D-sub 9 port on the rear of the unit for CANopen communications, shown in Rear interface labeled CANOPEN. The pinout for the D-sub 9 port is as follows:
Pin 2: CAN_L
Pin 3: CAN GND (isolated)
Pin 5: Shield GND
Pin 7: CAN_H
6.2.2. LED Codes
In the rear of the DBx Module is a communications interface with two exposed bi-color LEDs. The LED labeled RUN indicates status of the CANopen device and the one labeled ERR indicates CANopen communication errors, as shown in Rear interface. Status is indicated using colors and blink patterns, as shown in the tables below.
State |
Description |
|---|---|
Off |
No power or initializing |
Green |
Online, operational state |
Green, flashing |
Online, pre-operational state |
Green, 1 flash |
Online, stopped state |
Green, rapid flickering |
Baud rate detection or LSS in progress |
Red |
Fatal event |
State |
Description |
|---|---|
Off |
No power or no error |
Red, 1 flash |
Bus warning limit reached |
Red, 2 flashes |
Error control event |
Red, rapid flickering |
LSS in progress |
Red |
Bus off (fatal event) |
6.3. Data Objects
6.3.1. Process Data Objects (PDOs)
PDOs are real-time data frequently sent to and from connected Magna-Power Electronics nodes. When describing PDO traffic, it is referenced with respect to the CANopen slave node. For example, Transmit PDOs (TPDO) are transmitted from the slave and are read-only, while Receive PDOs (RPDO) transmits variables to the slave and have write access. Measurement readings would be mapped in the TPDO Mapping, whereas set points would be in the RPDO Mapping.
6.3.2. Service Data Objects (SDOs)
SDOs are messages sent on request and have no timing expectations. SDOs are intended for non-real-time communications, as they must wait for the network to respond. They are typically used for reporting the node status, changing operating modes, etc. SDOs variables should not be used to update values already part of a PDO, as they are updated regularly, and the values would be overwritten by the PDO.
6.4. CANopen State Machine
The master controls slaves by following the CANopen state machine. Slaves can transition between four states: Init, Pre-Operational, Operational, and Stopped. In each state, configuration checks are made and different types of communications are allowed. The transition between states are diagrammed in CANopen state machine. Allowed communications in each state is described in Allowed protocols for each state. Nodes enter Init when first switched-on and reach Operational under normal conditions.
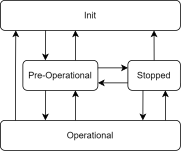
Fig. 6.2 CANopen state machine
State |
RSDO/TSDO |
TPDO |
RPDO |
|---|---|---|---|
Init |
|||
Pre-Operational |
✓ |
||
Operational |
✓ |
✓ |
✓ |
Stopped |
6.5. CANopen Default Node Settings
The default settings for Magna-Power Electronics CANopen nodes are as follows:
Node ID: 0x70
Data rate: 10 kbps
These settings can be changed using Layer Setting Services (LSS). The exact procedure for changing these settings is device-specific and can be found in your PLC’s user manual. The details needed to reconfigure Magna-Power Electronics CANopen nodes are found in Node details for LSS. Note that the serial number is a unique identifier for each node and can be found printed on on the product label or through the about menu. The serial used for LSS is the part of the serial number that is listed after the - symbol in the product’s serial number.
Property |
Value |
|---|---|
Vendor ID |
0x0000001B |
Product Code |
0x0000000D |
Revision Number |
0x00010002 |
Serial Number |
product serial (32-bit) |
6.6. Development using Python
Communication with Magna-Power Electronics CANopen nodes can be done using the canopen Python library. The library allows for communication using CANopen and can be used to read and write data to CANopen nodes. The library is available for download on the Python Package Index (PyPI) using the link: canopen
A compatible CAN interface is needed. A full list of compatible interfaces is listed in the canopen library’s documentation, found here. Internally, Magna-Power Electronics uses the Seeed Studio USB to CAN Analyzer (114991193) for its CANopen development and testing.
6.6.1. Device Setup
Ensure that the canopen library and any necessary drivers are installed on your system. In order to correctly access the node’s object dictionary, Magna-Power Electronics supplies an EDS file with your CANopen product.
Magna-Power Electronics EDS File
The following code snippet shows how to create a CANopen network and connect to a node with the default node ID of 0x70 and data rate of 10 kbps. Ensure that the bus type and channel are set to the correct values for your interface. This code snippet also assumes that the EDS file is in the same directory as the script.
import canopen

# Set the interface port and bitrate
INTERFACE_PORT = 'COM7'
BITRATE = 10000

# Create a CANopen network and connect to the node
network = canopen.Network()
network.connect(bustype='seeedstudio', channel=INTERFACE_PORT, bitrate=BITRATE)
mpeNode = canopen.RemoteNode(0x70, 'mpe_canopen.eds')
network.add_node(mpeNode)

# Set the SDO response timeout to 2 seconds
mpeNode.sdo.RESPONSE_TIMEOUT = 2

# Set the state of the node to pre-operational
 mpeNode.nmt.state = 'PRE-OPERATIONAL'

# Add code here to read/write data to the node

network.disconnect()
6.6.2. SDO Communication
The available SDO variables are listed in the Manufacturer Specific Service Data Objects section. The following code snippet shows how to read and write to an SDO variable.
# Read from an SDO variable
current = mpeNode.sdo['MeasCurrQ'].raw

# Write to an SDO variable
mpeNode.sdo['SetpointCurr'].raw = 1.5
For SDO variables with multiple subindices, the subindex can be accessed using the following syntax:
status0 = mpeNode.sdo["StatusRegQ"][1].raw
status1 = mpeNode.sdo["StatusRegQ"][2].raw
6.6.3. PDO Communication
The available PDO variables are listed in the Manufacturer Specific Process Data Objects section. Before enabling PDO communication, the PDO configuration must be read from the node. The following code snippet shows how to read the PDO configuration from the connected node.
# Read PDO configurations from node
mpeNode.tpdo.read()
mpeNode.rpdo.read()
Note that TPDO data is the data transmitted by the Magna-Power Electronics node, while RPDO is the data received by the node.
There are two main ways to access PDO data: using the sync method or by using up an event timer. The sync method` is used to sync the PDO data with the node when a sync command is sent by the master, while the event timer` is used to specify the interval at which the node should transmit and receive its PDO data. The following code snippet shows how to setup the sync method to read PDO data and print to the console. Note that sync commands can be sent manually, or at fixed intervals as shown in the code.
# Set TPDO 1's transmit mode to sync
mpeNode.sdo['TPDO communication parameter 1']['Transmission type'].raw = 1

# Send a single sync command to the node
network.sync.transmit()

# Set up sync timer for automatic sync transmission
network.sync.start(0.25)  # Sync every 0.25 seconds

# Change state to operational (NMT start)
mpeNode.nmt.state = 'OPERATIONAL'
The following code snippet uses an event timer to automatically transmit the data without the need for a sync command:
# Set TPDO 1's transmit mode to be internal-event triggered
mpeNode.sdo['TPDO communication parameter 1']['Transmission type'].raw = 255

# Set event timer to 250 ms
mpeNode.sdo['TPDO communication parameter 1']['Event timer'].raw = 250

# Change state to operational (NMT start)
mpeNode.nmt.state = 'OPERATIONAL'
6.6.4. Layer Setting Services (LSS)
Layer setting services (LSS) can be used to change the node ID and data rate of a target CANopen node to meet the demands of your network. There are two possible states for LSS: configuration and waiting. In the configuration state, the LSS master can change the node ID and data rate of the node. In the waiting state, the node operates normally.
There are two methods to bring a node into the configuration state. The first method is selective and requires knowledge of the connected node’s properties. These include the vendor ID, product code, revision number, and serial number. The default values for these properties can be found in Node details for LSS. To selectively request the node to enter the configuration state, the following code snippet can be used:
network.lss.send_switch_state_selective(vendorId=0x1B, productCode=0xD, revisionNumber=0x10002, serialNumber=SERIAL_NUMBER)
If the node’s properties are not known, users can globally request all connected nodes to enter the configuration state. The following code snippet can be used to globally request all connected nodes to enter the configuration state:
network.lss.send_switch_state_global(network.lss.CONFIGURATION_STATE)
Once a node is in the LSS configuration state, the node ID and data rate can be changed. The following code snippet shows how to change these settings:
# Change the node ID to 0x71
network.lss.configure_node_id(0x71)

# Change the data rate to 500 kbps
network.lss.configure_bit_timing(2)
Note that when setting the node ID, only one node should be connected to the CANopen network to prevent address conflicts. This node ID can be set to any value between 0x01 and 0x7F. Data rates are set based on bit-timing values, as shown in Bit timing values for different data rates.
idx |
Data rate |
|---|---|
8 |
10 kbps |
7 |
20 kbps |
6 |
50 kbps |
5 |
100 kbps |
4 |
125 kbps |
3 |
250 kbps |
2 |
500 kbps |
1 |
800 kbps |
0 |
1 Mbps |
Finally, once the node is configured, the settings can be saved and the nodes can be brought back into the operational state using the following code snippet:
network.lss.store_configuration()
network.lss.send_switch_state_global(network.lss.WAITING_STATE)
6.7. Standard Object Dictionary
The physical interface to a CANopen network is performed with an industrial communication module installed internal to the DBx Module. The module complies with version 4.2.0 of the CiA 301 specification. This specification calls for services and standard data object implementations outlined in the reference material below. The data objects reside in allocated address space shown in Data object dictionary
Network Interface Appendix Anybus CompactCom CANopen Doc.Id. SCM-1202-108
Index |
Object |
|---|---|
0x0000 |
Reserved |
0x001-0x025F |
Data types |
0x0260-0x0FFF |
Reserved |
0x1000-0x1FFF |
Communication profile area |
0x2000-0x5FFF |
Manufacturer specific profile area |
0x6000-0x9FFF |
Standardized device profile area |
0xA000-0xBFFF |
Standardized interface profile area |
0xC000-0xFFFF |
Reserved |
6.8. Manufacturer Specific Instances Listing
CANopen Command |
Write Index |
Read Index |
Description |
|---|---|---|---|
Operation Commands |
|||
N/A |
0x200B |
Returns the value of the Questionable Status register |
|
N/A |
0x200C |
Returns the value of the Operation Status register |
|
N/A |
0x200D |
Status Register |
|
0x200F |
0x2010 |
||
Measurement Commands |
|||
N/A |
0x2101 |
Measures and returns the average current at the sense location |
|
N/A |
0x2102 |
Measures and returns the average voltage at the sense location |
|
N/A |
0x2103 |
Measures and returns the instantaneous DC power at sense location |
|
Setpoint Commands |
|||
0x2201 |
0x2202 |
Sets the current set-point |
|
0x2203 |
0x2204 |
Sets the voltage set-point |
|
0x2205 |
0x2206 |
Sets the power set-point |
|
Trip Commands |
|||
0x2301 |
0x2302 |
Sets the over current trip (OCT) set-point |
|
0x2303 |
0x2304 |
Sets the over voltage trip (OVT) set-point |
|
0x2305 |
0x2306 |
Sets the over power trip (OPT) set-point |
|
0x2307 |
0x2308 |
Sets the under voltage trip (UVT) set-point |
|
Slew Commands |
|||
0x2401 |
0x2402 |
Sets the rising slew rate for current when in current regulation state |
|
0x2403 |
0x2404 |
Sets the rising slew rate for voltage when in voltage regulation state |
|
0x2405 |
0x2406 |
Sets the rising slew rate for power when in power regulation state |
|
0x2409 |
0x240A |
Sets the falling slew rate for current when in current regulation state |
|
0x240B |
0x240C |
Sets the falling slew rate for voltage when in voltage regulation state |
|
0x240D |
0x240E |
Sets the falling slew rate for power when in power regulation |
|
0x2701 |
N/A |
Restores the factory EEPROM data |
|
0x2703 |
0x2702 |
Locks and unlocks the product from configuration and set-point changes |
|
0x2706 |
0x2707 |
Configures the sense location and automated compensation values |
|
0x2708 |
0x2709 |
Changes the communication protocol |
|
0x270A |
0x270B |
Sets the setpoint source |
|
0x270C |
0x270D |
Changes the MagnaLINK mode to allow for standalone or master-slave configuration |
|
0x270E |
N/A |
Reinitialize all connected slaves |
6.9. Manufacturer Specific Process Data Objects
6.9.1. Operation Commands
6.9.2. StatusRegQ
This command queries the Status Register. This read-only register holds the live (unlatched) operation status of the Accessory. Issuing a query does not clear the register. The register location and definitions are subject to change after any firmware release to accommodate new features. The Questionable Register is a subset of the status register and does not change between firmware updates. The present bit assignments are shown in the table below.
- Access:
RO
- Data Format:
32-bit Integer
Status Register 0
Bit |
Name |
Description |
|---|---|---|
0 |
standby |
output is in standby |
1 |
live |
output is active |
2 |
solenoidStatus |
aux power solenoid is open |
3 |
nonhalt2 |
available |
4 |
overCurrTrip |
over current trip |
5 |
overVoltTrip |
over voltage trip |
6 |
overPwrTrip |
over power trip |
7 |
remoteSenseLoss |
remote sense voltage outside of acceptable bounds |
8 |
underVoltTrip |
under voltage trip |
9 |
shutdown |
target is creating a shutdown condition |
10 |
linPwrLim |
power across linear modules exceed ratings |
11 |
resPwrLim |
power across resistors exceed ratings |
12 |
bootFailure |
one or multiple target did not boot up |
13 |
bootState |
one or more targets are waiting to boot |
14 |
phaseCurr |
rated phase current exceeded |
15 |
comm |
communications are corrupted |
16 |
overCurrProtect |
terminal current exceeded product rating |
17 |
overVoltProtect |
terminal voltage exceeded product rating |
18 |
tempRLin |
linear module exceeded temperature |
19 |
blownFuse |
fuse is blown on the auxiliary power supply |
20 |
interlock |
interlock open |
21 |
haltUserClear |
available |
22 |
maintenance |
maintenance |
23 |
tempDMod |
diode modules exceeded temperature |
24 |
incompatibleSysConfig |
incompatible system configuration |
25 |
stackOverflow |
exceeded firmware stack |
26 |
lineFault |
line fault analog/digital inputs |
27 |
tempRMod |
resistor module exceeded temperature |
28 |
belowRatedMinVolt |
below minimum voltage rating(28) |
29 |
outOfRegulation |
out of regulation, unexpected currents measured |
30 |
targetUpgrade |
mainctrl upgrading other targets |
31 |
haltSelfClear |
available |
Status Register 1
Bit |
Name |
Description |
|---|---|---|
0 |
phaseLoss |
one or more phase missing |
1 |
blownFuseInput |
input fuse blown on fuse/emi filter |
2 |
fanLockedRotor |
one or more fan’s rotor has locked |
3 |
notUsed29 |
available |
4 |
tempPwrMod |
power processing module temperature fault |
5 |
tempOutputMod |
output filter module temperature fault |
6 |
tempOutputCap |
output capacitors temperature fault |
7 |
tempTransformer |
transformer exceeded temperature fault |
8 |
notUsed26 |
available |
9 |
notUsed27 |
available |
10 |
notUsed28 |
available |
11 |
notUsed1 |
available |
12 |
notUsed2 |
available |
13 |
notUsed3 |
available |
14 |
notUsed4 |
available |
15 |
notUsed5 |
available |
16 |
invalidSysRating |
invalid system rating |
17 |
fwVersConflict |
firmware version conflict |
18 |
notUsed8 |
available |
19 |
notUsed9 |
available |
20 |
notUsed10 |
available |
21 |
notUsed11 |
available |
22 |
notUsed12 |
available |
23 |
notUsed13 |
available |
24 |
notUsed14 |
available |
25 |
notUsed15 |
available |
26 |
notUsed16 |
available |
27 |
notUsed17 |
available |
28 |
notUsed18 |
available |
29 |
notUsed19 |
available |
30 |
notUsed20 |
available |
31 |
notUsed21 |
available |
6.9.3. Measurement Commands
6.9.4. MeasCurrQ
This query commands the Accessory to measure and return the average current through the DC terminals.
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.9.5. MeasVoltQ
This query commands commands the Accessory to measure and return the average voltage at the DC terminals. If the remote sense function is used and engaged, this command returns the voltage measured at the sense terminals.
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.9.6. Setpoint Commands
6.9.7. SetpointCurr
This command programs the current set-point that the Accessory will regulate to when operating in constant current mode.
- Access:
RW
- Data Format:
32-bit Floating Point Number
6.9.8. SetpointVolt
This command programs the voltage set-point, in volts, which the Accessory will regulate to when operating in constant voltage mode.
- Access:
RW
- Data Format:
32-bit Floating Point Number
6.10. Manufacturer Specific Service Data Objects
6.10.1. Operation Commands
6.10.1.1. StatusQuesQ
This command queries and returns the values of the Questionable Register. This read-only register holds the live (unlatched) questionable statuses of the Accessory. Issuing this query does not clear the register. The bit configuration of the Questionable Register is shown in the table below.
- Index:
0x200B
- Access:
RO
- Data Format:
32-bit Integer
Questionable Register
Bit |
Weight |
Abbreviation |
Description |
|---|---|---|---|
0 |
1 |
OVP |
over voltage protection, hard fault |
1 |
2 |
OCT |
over current trip, soft fault |
2 |
4 |
OVT |
over voltage trip, soft fault |
3 |
8 |
OPT |
over power trip, soft fault |
4 |
16 |
OCP |
over current protection, hard fault |
5 |
32 |
OTP |
over temperature protection, hard fault |
6 |
64 |
RSL |
remote sense loss, soft fault |
7 |
128 |
SFLT |
soft fault, the ord value of all soft faults |
8 |
256 |
HFLT |
hard fault, the ord value of all hard faults |
9 |
512 |
ILOC |
interlock open, soft fault |
10 |
1024 |
IPL |
input power loss fault, hard fault |
11 |
2048 |
ADIF |
analog or digital input fault, hard fault |
6.10.1.2. StatusOperQ
This command queries and returns the values of the Operation Register. This read-only register holds the live (unlatched) operation statuses of the Accessory. Issuing this query does not clear the register. The bit configuration of the Operation Register is shown in the table below.
- Index:
0x200C
- Access:
RO
- Data Format:
32-bit Integer
Operation Register
Bit |
Weight |
Abbreviation |
Description |
|---|---|---|---|
0 |
1 |
STBY |
standby |
1 |
2 |
EN |
enabled |
2 |
4 |
RSEN |
remote sense |
3 |
8 |
LOCK |
front panel locked |
4 |
16 |
CC |
constant current regulation, regulation status |
5 |
32 |
CV |
constant voltage regulation, regulation status |
6 |
64 |
CR |
constant resistance regulation, regulation status |
7 |
128 |
CP |
constant power regulation, regulation status |
6.10.1.3. StatusRegQ
This command queries the Status Register. This read-only register holds the live (unlatched) operation status of the Accessory. Issuing a query does not clear the register. The register location and definitions are subject to change after any firmware release to accommodate new features. The Questionable Register is a subset of the status register and does not change between firmware updates. The present bit assignments are shown in the table below.
- Index:
0x200D
- Access:
RO
- Data Format:
32-bit Integer
Status Register 0
Bit |
Name |
Description |
|---|---|---|
0 |
standby |
output is in standby |
1 |
live |
output is active |
2 |
solenoidStatus |
aux power solenoid is open |
3 |
nonhalt2 |
available |
4 |
overCurrTrip |
over current trip |
5 |
overVoltTrip |
over voltage trip |
6 |
overPwrTrip |
over power trip |
7 |
remoteSenseLoss |
remote sense voltage outside of acceptable bounds |
8 |
underVoltTrip |
under voltage trip |
9 |
shutdown |
target is creating a shutdown condition |
10 |
linPwrLim |
power across linear modules exceed ratings |
11 |
resPwrLim |
power across resistors exceed ratings |
12 |
bootFailure |
one or multiple target did not boot up |
13 |
bootState |
one or more targets are waiting to boot |
14 |
phaseCurr |
rated phase current exceeded |
15 |
comm |
communications are corrupted |
16 |
overCurrProtect |
terminal current exceeded product rating |
17 |
overVoltProtect |
terminal voltage exceeded product rating |
18 |
tempRLin |
linear module exceeded temperature |
19 |
blownFuse |
fuse is blown on the auxiliary power supply |
20 |
interlock |
interlock open |
21 |
haltUserClear |
available |
22 |
maintenance |
maintenance |
23 |
tempDMod |
diode modules exceeded temperature |
24 |
incompatibleSysConfig |
incompatible system configuration |
25 |
stackOverflow |
exceeded firmware stack |
26 |
lineFault |
line fault analog/digital inputs |
27 |
tempRMod |
resistor module exceeded temperature |
28 |
belowRatedMinVolt |
below minimum voltage rating(28) |
29 |
outOfRegulation |
out of regulation, unexpected currents measured |
30 |
targetUpgrade |
mainctrl upgrading other targets |
31 |
haltSelfClear |
available |
Status Register 1
Bit |
Name |
Description |
|---|---|---|
0 |
phaseLoss |
one or more phase missing |
1 |
blownFuseInput |
input fuse blown on fuse/emi filter |
2 |
fanLockedRotor |
one or more fan’s rotor has locked |
3 |
notUsed29 |
available |
4 |
tempPwrMod |
power processing module temperature fault |
5 |
tempOutputMod |
output filter module temperature fault |
6 |
tempOutputCap |
output capacitors temperature fault |
7 |
tempTransformer |
transformer exceeded temperature fault |
8 |
notUsed26 |
available |
9 |
notUsed27 |
available |
10 |
notUsed28 |
available |
11 |
notUsed1 |
available |
12 |
notUsed2 |
available |
13 |
notUsed3 |
available |
14 |
notUsed4 |
available |
15 |
notUsed5 |
available |
16 |
invalidSysRating |
invalid system rating |
17 |
fwVersConflict |
firmware version conflict |
18 |
notUsed8 |
available |
19 |
notUsed9 |
available |
20 |
notUsed10 |
available |
21 |
notUsed11 |
available |
22 |
notUsed12 |
available |
23 |
notUsed13 |
available |
24 |
notUsed14 |
available |
25 |
notUsed15 |
available |
26 |
notUsed16 |
available |
27 |
notUsed17 |
available |
28 |
notUsed18 |
available |
29 |
notUsed19 |
available |
30 |
notUsed20 |
available |
31 |
notUsed21 |
available |
6.10.1.4. Output
This command enables or disables the Accessory output. A 1 indicates the product’s power processing circuit is active and processing power, while and a 0 indicates the power supply is in standby or faulted state.
- Index:
0x200F
- Access:
RW
- Data Format:
Boolean
- Index:
0x2010
- Access:
RO
- Data Format:
Boolean
6.10.2. Measurement Commands
6.10.2.1. MeasCurrQ
This query commands the Accessory to measure and return the average current through the DC terminals.
- Index:
0x2101
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.2.2. MeasVoltQ
This query commands commands the Accessory to measure and return the average voltage at the DC terminals. If the remote sense function is used and engaged, this command returns the voltage measured at the sense terminals.
- Index:
0x2102
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.2.3. MeasPwrQ
This query commands commands the Accessory to measure and return the average power at the DC terminals.
- Index:
0x2103
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.3. Setpoint Commands
6.10.3.1. SetpointCurr
This command programs the current set-point that the Accessory will regulate to when operating in constant current mode.
- Index:
0x2201
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2202
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.3.2. SetpointVolt
This command programs the voltage set-point, in volts, which the Accessory will regulate to when operating in constant voltage mode.
- Index:
0x2203
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2204
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.3.3. SetpointPwr
This command programs the power set-point, in watts, which the Accessory will regulate to when operating in constant power mode.
- Index:
0x2205
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2206
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.4. Trip Commands
6.10.4.1. OverTripCurr
This command programs the over current trip (OCT) set-point. If the input current exceeds the over current trip set-point for multiple samples, the input is disconnected and an OCT fault is indicated.
- Index:
0x2301
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2302
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.4.2. OverTripVolt
This command programs the over voltage trip (OVT) set-point. If the input voltage exceeds the over voltage trip set-point for multiple samples, the input is disconnected and an OVT fault is indicated.
- Index:
0x2303
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2304
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.4.3. OverTripPwr
This command programs the over power trip (OPT) set-point. If the input power exceeds the over power trip set-point for multiple sample, the input is disconnected and an OPT fault is indicated.
- Index:
0x2305
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2306
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.4.4. UnderTripVolt
This command programs the under voltage trip (UVT) set-point. If the input voltage falls below the under voltage trip set-point for multiple samples, the input is disconnected and an UVT fault is indicated.
- Index:
0x2307
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2308
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5. Slew Commands
6.10.5.1. RiseRampCurr
This command sets the current slew rate for increasing current transitions while in constant current regulation. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x2401
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2402
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.2. RiseRampVolt
This command sets the voltage slew rate for increasing voltage transitions while in constant voltage regulation. The units for voltage slew rate are volts per millisecond. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x2403
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2404
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.3. RiseRampPwr
This command sets the power slew rate for increasing power transitions while in constant power regulation. The units for power slew rate are watts per millisecond. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x2405
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x2406
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.4. FallRampCurr
This command sets the current slew rate for decreasing current transitions while in constant current regulation. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x2409
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x240A
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.5. FallRampVolt
This command sets the voltage slew rate for decreasing voltage transitions while in constant voltage regulation. The units for voltage slew rate are volts per millisecond. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x240B
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x240C
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.6. FallRampPwr
This command sets the power slew rate for decreasing power transitions while in constant power regulation. The units for power slew rate are watts per millisecond. MAXimum sets the slew to the fastest possible rate. MINimum sets the slew to the slowest rate. Slew rates less than the minimum value are set to MINimum. Slew rate settings less than the minimum value are set to MINimum. Slew rate settings greater than the maximum value are set to MAXimum.
- Index:
0x240D
- Access:
RW
- Data Format:
32-bit Floating Point Number
- Index:
0x240E
- Access:
RO
- Data Format:
32-bit Floating Point Number
6.10.5.7. FactoryRestore
This command performs a factory restore to default EPROM values. Both Soft Restore and Hard Restore are available through command parameters.
- Index:
0x2701
- Access:
RW
- Data Format:
16-bit Integer
6.10.5.8. Lock
This command configures the Accessory’s lock state. While locked, the stop button is the only functional button on the front panel. See Lock for more details on how lock works and how behaves relative to other locking inputs (front panel and digital input).
- Index:
0x2703
- Access:
RW
- Data Format:
Boolean
- Index:
0x2702
- Access:
RO
- Data Format:
Boolean
6.10.5.9. SenseMode
This command configures where the Accessory senses voltage. The sense location also effects how power and resistance are calculated. Local sensing monitors the directly across the output terminals. Remote sensing, as described in Remote Sense Connection, measures across the terminal JS2. This external connection can be used to improve regulation at the point of load, as is needed for example, in compensating voltage drops caused by wire resistance.
- Index:
0x2706
- Access:
RW
- Data Format:
16-bit Integer
- Index:
0x2707
- Access:
RO
- Data Format:
16-bit Integer
6.10.5.10. CommProt
This command changes the command protocol of the Accessory.
- Index:
0x2708
- Access:
RW
- Data Format:
16-bit Integer
- Index:
0x2709
- Access:
RO
- Data Format:
16-bit Integer
6.10.5.11. SetSource
The command selects and routes different set points sources to the digital controller. Operation of this feature is described in Set Point Source. By default, the source is set to local (value 0), where set points originating from the front panel or communication interfaces are routed to the DBx Module digital control. When the source is set to function generator (value 1), set points are generated internally, by a periodic function generator block. When external analog input (value 3) is set, the voltage(s) applied to the rear connector are converted into set points.
- Index:
0x270A
- Access:
RW
- Data Format:
16-bit Integer
- Index:
0x270B
- Access:
RO
- Data Format:
16-bit Integer
6.10.5.12. MagnaLinkMode
This command changes the MagnaLINK mode to allow for standalone or master-slave configurations.
- Index:
0x270C
- Access:
RW
- Data Format:
16-bit Integer
- Index:
0x270D
- Access:
RO
- Data Format:
16-bit Integer
6.10.5.13. MagnaLinkReinit
This command should be used to reinitialize system ratings when a slave is added or removed from a master-slave configuration.
- Index:
0x270E
- Access:
RW
- Data Format:
16-bit Integer